
Binglun Wang, Doğa Yılmaz, Niloy Mitra, Edmond S. L. Ho, He Wang
Preprint, 2026
Project Page / Preprint
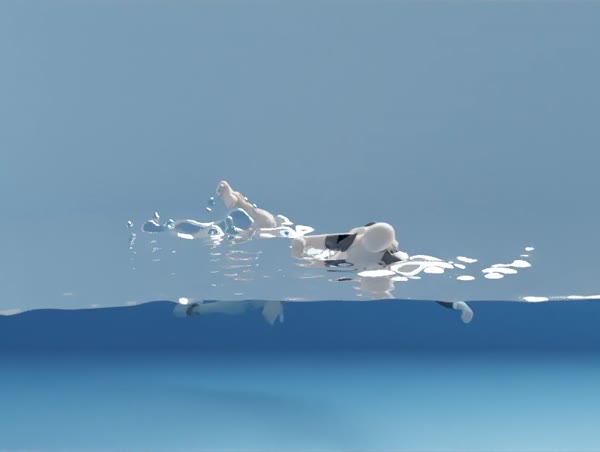
A framework for reinforcement learning of human swimming control. Our main contributions are: (1) the first work to learn stable, controllable, and natural full-body swimming policies, from only a single reference motion; and (2) a novel body–water environment representation that enables this learning. SWIM achieves improved stability, goal satisfaction, and physical realism, with a 63.9% success rate on held-out generalization, compared with 36.8% for the strongest baseline.
